Torque, Inertia and Hot Enclosures: Five Servo Sizing Shortcuts Worth Retiring
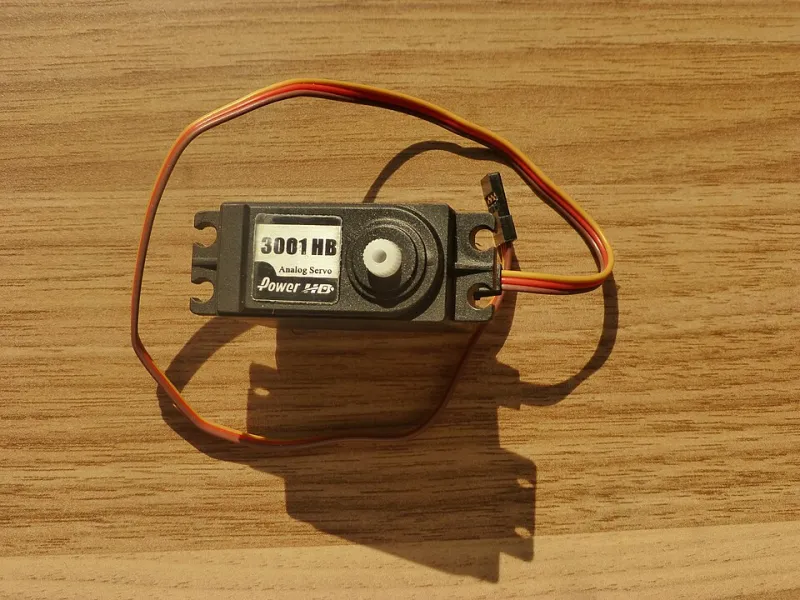
Photo: Nevit Dilmen (talk), CC BY-SA 3.0, via Wikimedia Commons
Servo sizing rarely fails because the sums were done badly. It fails because the sums were done on the wrong model. The shortcuts below are common, superficially reasonable and individually capable of taking a machine from concept to a commissioning week that nobody enjoys. Each one has a replacement that is not much more work.
Assumption one: nameplate torque is your design torque
Peak torque on a datasheet is a transient figure, qualified by duration and by the drive's current limit. Continuous torque is qualified by mounting, cooling and ambient. Selecting on the larger of the two numbers, or on a single figure copied from a catalogue table, tells you almost nothing about whether the motor will survive the cycle.
The replacement is the duty-cycle RMS calculation: break the cycle into segments, take the torque and duration of each, square and time-weight them, and add a margin. Then check the result against the continuous torque available in the actual installation arrangement — flange-mounted in still air, mounted to a gearbox, or force-cooled all give different answers. Check the peak segments separately against the motor's permissible overload and the drive's current rating, and check the thermal time constant against the segment duration: a short overload on a small motor heats differently from the same overload on a large one.
Assumption two: reflected inertia is a detail for the integrator
The load inertia seen by the motor is the load inertia divided by the square of the gear ratio, plus the motor's own inertia. That squared term is the whole point, and it is where optimistic assumptions creep in — particularly on belt-driven and rack-and-pinion axes where the reflected inertia of a translating mass can dominate the calculation entirely.
When the mismatch is large, the symptoms appear as tuning that will not settle, gain that has to be wound back until the axis is sluggish, audible resonance, and a gearbox working harder than its rating suggests. The fix is to calculate the ratio explicitly and then size the gearbox — not the motor alone — to bring it into a sensible band. If the inertia ratio cannot be brought down by gearing, the drive's tuning and filter functions can help, but they are compensating for a selection decision rather than correcting it.
Assumption three: the braking resistor can be sized later
On a vertical axis, every descent is a generating event. The energy goes into the DC link, and if the resistor and chopper cannot absorb it at the rate it arrives, the drive trips on overvoltage — usually during a run-off at the end of commissioning, when the schedule is tightest.
Sizing is a two-part calculation: the energy per cycle and the average power over the cycle. A common error is to size on average power alone, which produces a resistor that is quiet in steady production but fails on repeated fast descents. The second error is to size on energy alone and then discover the continuous rating is exceeded during a long lowering move.
Work out both from the axis data — moving mass, travel, acceleration profile, cycle time — then confirm against the drive's permitted braking resistor range and its chopper duty. Where the duty is continuous or closely spaced, a regenerative supply module that returns energy to the supply is often the more sensible architecture than a large resistor dissipating heat into a sealed enclosure.
Assumption four: it will be 40 °C in the panel
Forty degrees is a useful default for a datasheet derating table. It is not a measurement. Inside a sealed IP54 enclosure, with a servo drive, a power supply, a braking resistor and a PLC, in a plant room that warms up through a July afternoon, the air around the drive heatsink is frequently well above the figure assumed at concept stage. Adding any filter fans or air-conditioning later is far more expensive than allowing for it at design.
The practical answer is a simple thermal calculation — total losses in the enclosure, surface area, any forced ventilation — followed by a week of logging with a datalogger positioned where the drive will sit, not where the panel builder's thermometer happened to be. Log through a warm spell and through a weekend shutdown, because the restart after a hot weekend is often when the fan fails. Then apply derating for both ambient and altitude, and check the motor's permitted ambient as well: a servo in a guarded cell next to a heat source faces the same question as the drive.
Assumption five: holding torque is continuous torque
A permanent-magnet holding brake is a parking device. It is designed to hold a stationary load, not to arrest a moving one, and not to be energised and de-energised at production rate. Treating it as a continuous clamp means friction faces wear, air gaps grow, and the axis starts to sag between cycles — a fault that often gets investigated as a tuning problem before anyone looks at the brake.
Keep the two functions separate. The servo provides the torque for the process; the brake holds position when the drive is disabled, at power-down, or during maintenance. Then check the switching work per hour against the brake's rating, and use a counterbalance or a mechanical clamp where the load genuinely has to be held for long periods. On vertical axes this is also a safety question, and the guarding and control arrangements should be assessed against BS EN 60204-1 with the brake treated as one element of the arrangement rather than the whole answer.
What to do differently on the next build
None of these replacements add much engineering time. Duty-cycle RMS, an explicit inertia ratio, a two-part braking energy calculation, a logged enclosure temperature and a clear separation of holding from process torque together cover the majority of the sizing failures that reach site. Building them into the concept stage, before the drive is ordered, is the cheapest moment to get them right.